
Autonomy & Navigation
Fieldwork — Visual Localization
Terrain-relative navigation · digital shadow
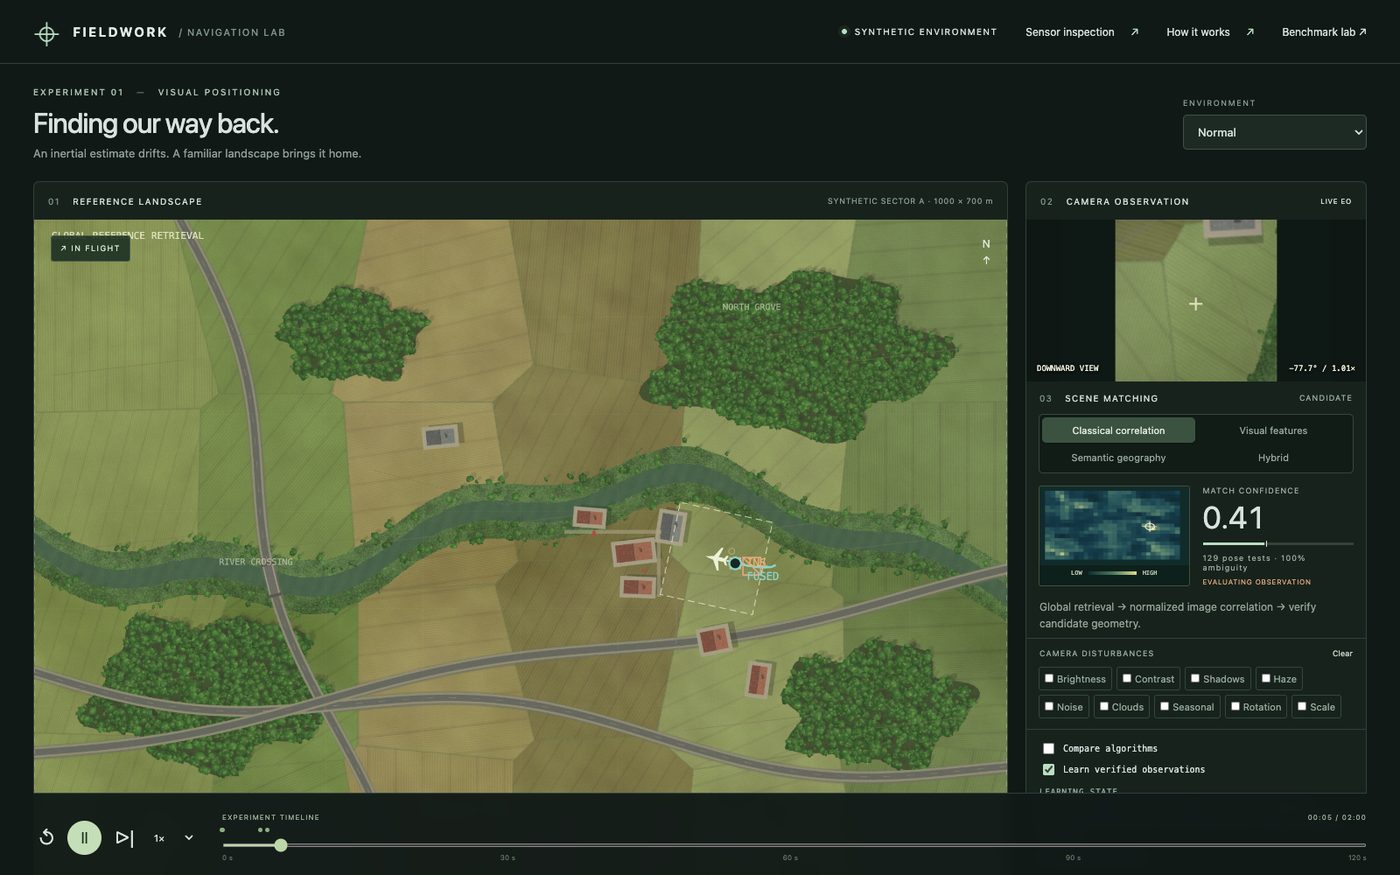
Where is the vehicle, given only what its camera sees? Reference and live images are independent renders of the same synthetic terrain; classical, feature-based, semantic and hybrid localisers correct an inertial drift, with measured error bounds.